Differences between CAN and CAN FD
CAN Concept:
CAN, short for Controller Area Network, is a serial communication protocol designed for automotive electronic systems. It was developed by the German electrical engineering company Bosch in 1983 and officially introduced in 1986. The CAN protocol is primarily used for communication among electronic control units (ECUs) in vehicles, enabling data exchange between various electronic devices and systems.
Key features of the CAN protocol include:
Multi-Master Control: In a CAN network, any node can send information at any time without requiring scheduling from a central control unit.
Message Arbitration: When two or more nodes transmit data simultaneously, an arbitration mechanism ensures that higher-priority messages are transmitted firstly.
Error Detection and Handling: The CAN protocol provides robust error detection capabilities, including bit error detection, frame error detection, and CRC (Cyclic Redundancy Check), ensuring reliable data transmission.
Flexible Topology: CAN networks can adopt bus, star, or hybrid topologies, facilitating wiring within vehicles.
Data Transfer Rate: CAN supports various data transfer rates, ranging from a minimum of 10 kbps to a maximum of 1 Mbps, accommodating diverse application requirements. Support for Multiple Communication Modes: Includes point-to-point, point-to-multipoint, and broadcast communication modes.
Network Scalability: CAN networks can be easily expanded using repeaters or bridges to support additional nodes.
Cost-Effectiveness: The hardware and software implementation of the CAN protocol is relatively low-cost, making it suitable for large-scale applications.
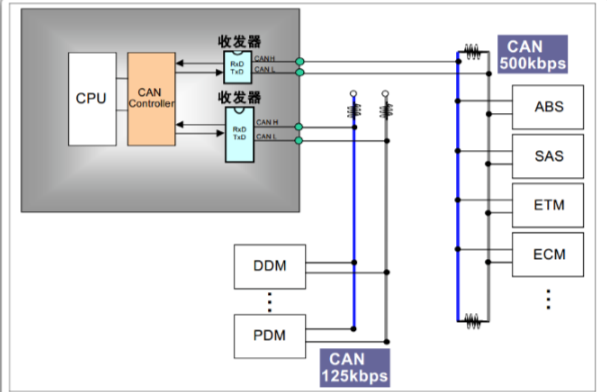
Due to its high reliability, real-time performance, and flexibility, the CAN protocol is not only widely used in the automotive industry, but also applied in various fields such as industrial,automa-tion, medical devices, and home automation. With technological advancements,the CAN protocol continues to be improved and extended to meet a broader range of application requirements.
CAN FD Concept:
CAN FD (CAN with Flexible Datarate) is a communication protocol designed to meet the increasing data transmission demands in modern automotive systems. It is an extension of the traditional CAN (Controller Area Network) protocol, with key improvements including higher data transfer rates and larger data frame sizes.
Higher Data Transfer Rate: CAN FD supports transmission rates significantly exceeding the traditional CAN maximum of 1 Mbps. The data phase rate can reach up to 8 Mbps.
Larger Data Frame Size: CAN FD allows up to 64 bytes of data per frame, compared to the traditional CAN limit of 8 bytes.
Dual Bit Rate: CAN FD uses two different bit rates within a single frame. The arbitration phase (ensuring correct message priority transmission) uses a lower rate, while the data phase can operate at a higher rate.
Enhanced Reliability: Improved data transmission reliability is achieved through an enhanced Cyclic Redundancy Check (CRC) and other error detection mechanisms.
Backward Compatibility: CAN FD devices can communicate with devices that only support traditional CAN on the same network, although the full benefits of CAN FD will not be utilized in such mixed scenarios.

Due to its high data rates and large payload capacity, CAN FD is particularly suitable for automotive applications requiring substantial data transmission, such as high-definition camera data transfer, infotainment systems, advanced driver assistance systems (ADAS),and autonomous driving technologies.